Research
My research interests lie in the robotic automation of dental surgery, including kinematics optimzation, path planning, reinforcement learning, and human-robot-interaction control.
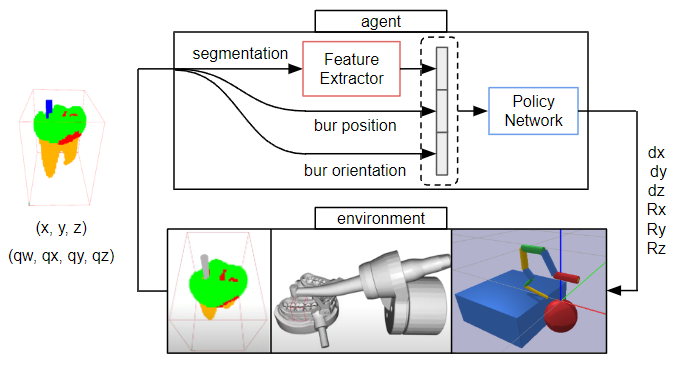
Cavity Removal Path Planning using Imitation Reinforcement Learning (CRPIR), a novel framework combining imitation learning (IL) and reinforcement learning (RL) to generate cut paths for cavity removal.
A framework for the kinematic and functional optimization of dental robotic systems using Particle Swarm Optimization (PSO) and Genetic Algorithm (GA), which is parameterized by trajectory requirements and performance measures, ensuring adaptability for diverse robotic automation applications.
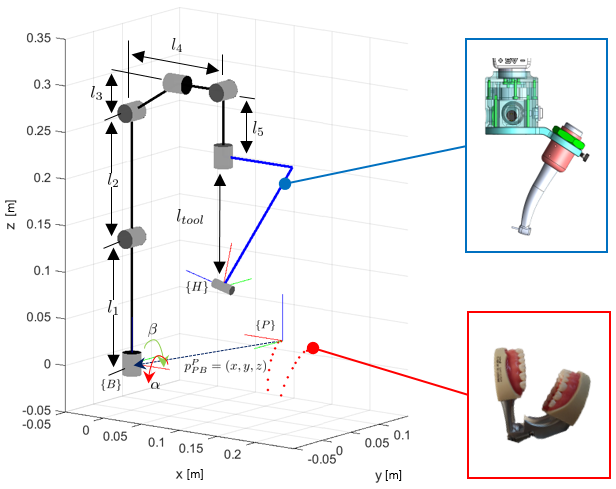
Kinematic calibration methods to improve the accuracy of robotic tooth preparation based on Modified Denavit-Hartenberg (MDH) parameters and local Product of Exponential (POE) formulation.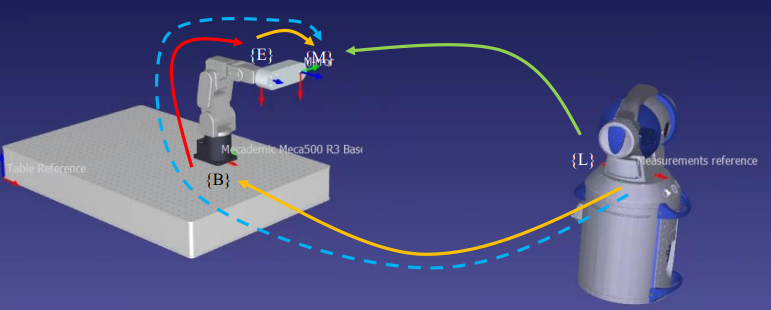
[TBD] Admittance Control for Human-Robot-Interaction in Macro-Micro Dental Robotic System.
[TBD] Model Predictive Path-Following Control for Robotic Tooth Preparation.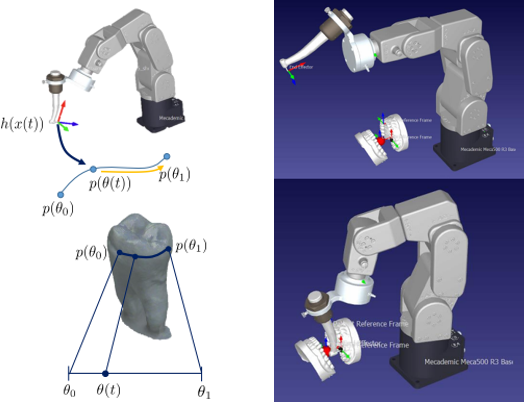
Robust hand tracking system fusing complementary strengths of visual and inertial sensors. The system addresses limitations of individual sensing modalities and provides an effective solution for Human-Robot Interaction (HRI) interfaces.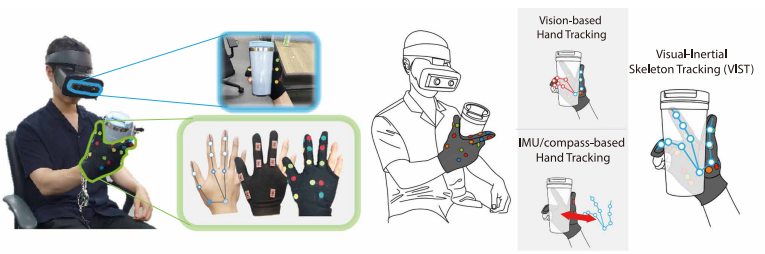
Development of a 6-DoF collaborative robot manipulator designed for versatile applications, including automation in the Food & Beverage industry and Robot Production Systems. The robot incorporates safety features and advanced vision capabilities to enhance human-robot interaction and operational efficiency.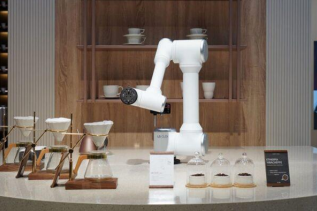
Development of an origami-inspired robotic manipulator with a folding and unfolding mechanism. This design enhances mobility in the folded state for mobile robots and improves manipulability in the unfolded state, making it suitable for volume-efficient and human-interactable applications such as warehouse operations.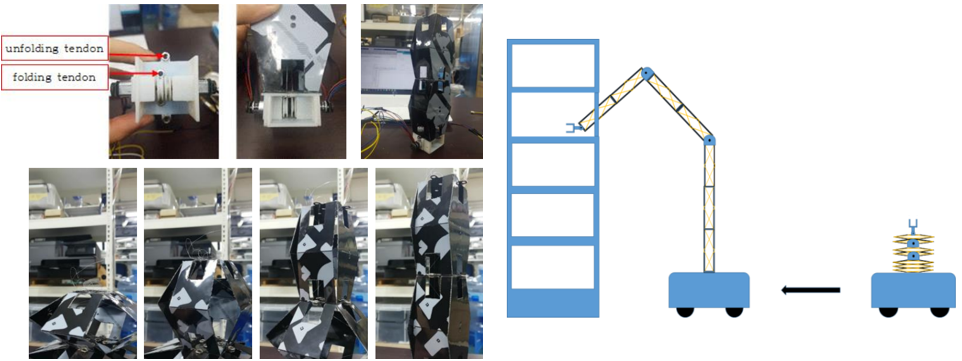
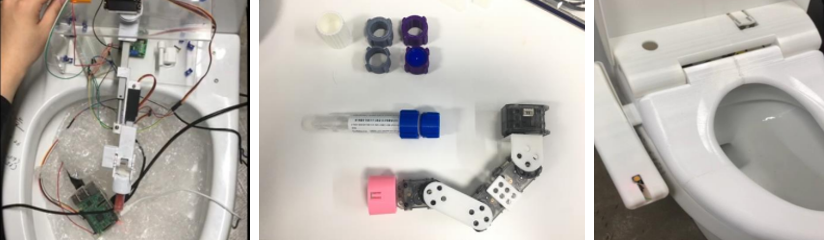
Development of an autonomous, real-time microbiome diagnosis system that integrates a robotic manipulator for fecal sampling with a third-generation DNA sequencer for microbiome analysis.
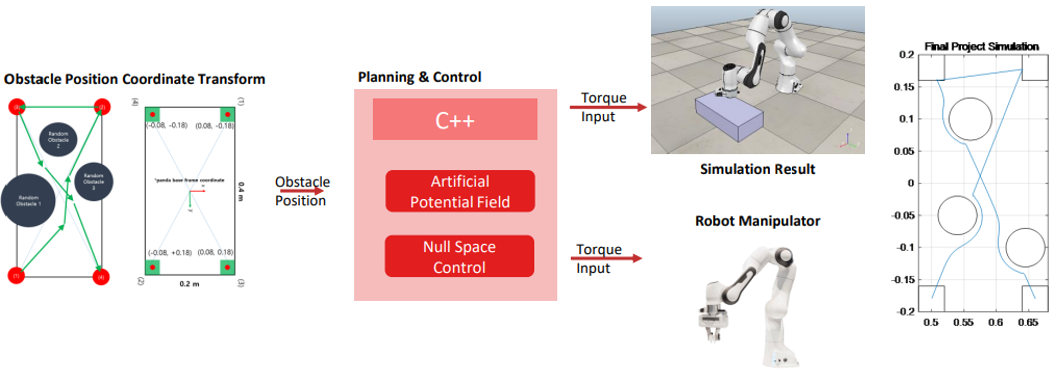
Designed and implemented an obstacle-avoidance control algorithm with two hierarchical objectives, utilizing null space control to guide the manipulator’s end-effector through four different destinations while avoiding randomly distributed obstacles.