Robot Manipulator Obstacle Avoidance Control
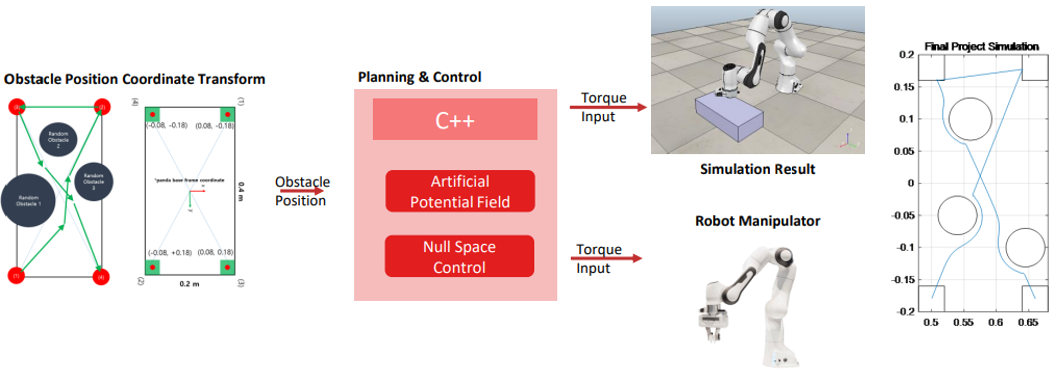
Designed and implemented an obstacle-avoidance control algorithm with two hierarchical objectives, utilizing null space control to guide the manipulator’s end-effector through four different destinations while avoiding randomly distributed obstacles.
- Motivation
- Addressing the challenge of controlling a robot manipulator in environments with obstacles while ensuring the completion of desired tasks.
- Contributions
- Developed a robust safety control algorithm for a robot manipulator, employing artificial potential fields to generate repelling forces around obstacles.
- Achieved reliable control while preserving the initial configuration of the end-effector to avoid singularities, using a null space control method.
- Skills:
- Artifical Potenital Field Obstacle Avoidance, Robot Dynamics, Null Space Control
- Tools: C/C++, MATLAB, CoppeliaSim