Kinematics and Functional Optimization of Dental Robotics
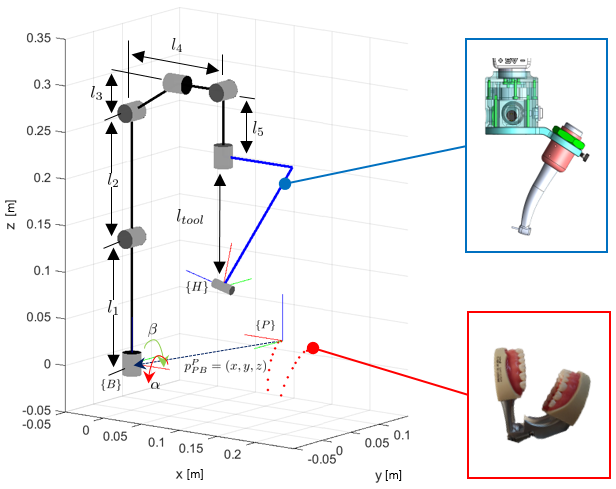
This project presents a comprehensive framework for the kinematic and functional optimization of dental robotic systems using Particle Swarm Optimization (PSO) and Genetic Algorithm (GA). The framework is parameterized by trajectory requirements and performance measures, ensuring adaptability for diverse robotic automation applications. This research is the first to define the optimal kinematics and installation base pose of a robotic manipulator for decay removal and tooth preparation. The proposed methodology can be generalized for various robotic automation tasks by adjusting its parameters to fit specific applications.
- Motivation
- Robotics in dentistry has significant potential to enhance the precision and efficiency of dental procedures.
- Robotic automation of specific dental tasks, such as decay removal and tooth preparation, requires careful consideration of the kinematic design and installation base pose of robot manipulators.
- Optimal design is essential for executing dexterous robotic motions that generate freeform tooth surfaces while accommodating complex clinical requirements such as patient comfort and collision avoidance.
- Contributions
- Conducted the first study defining the optimal kinematics and base pose of robot manipulator for decay removal and tooth preparation in dental surgery.
- Proposed a generic framework for kinematics and functional optimization of dental robotic systems, adaptable to various robotic applications.
- Developed task-specific performance measures of robot manipulator, allowing for the quantitative evaluation of a robotic system for a given task.
- Validated the optimization framework through qualitative and quantitative analyses, including Monte Carlo simulations and physical experiments on tooth preparation.
- Skills:
- Optimization, Robot Manipulator Performance Measures.
- Programming Language: Python, MATLAB.
- Tools: Robotics Toolbox, PySwarms, PyGAD, PyBullet.