Kinematics Calibration for Robotic Tooth Preparation
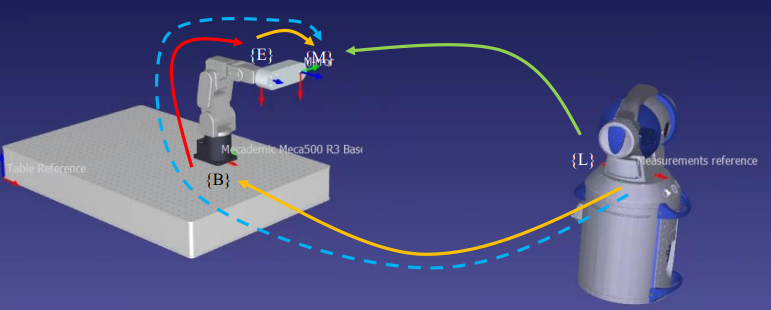
Kinematic calibration methods to improve the accuracy of robotic tooth preparation based on Modified Denavit-Hartenberg (MDH) parameters and local Product of Exponential (POE) formulation.
- Motivation
- Addressing the need for precise robotic tooth preparation by improving accuracy within the robot’s workspace.
- Contributions
- Designed and implemented a calibration point generation algorithm to enhance accuracy of robot in tooth preparation workspace.
- Implemented a rotary joint axis estimation algorithm [1].
- Developed a kinematic calibration algorithm based on Modified Denavit-Hartenberg (MDH) parameters, incorporating an additional parameter 𝛽 2.
- Implemented kinematics calibration algorithm based on local Product of Exponential (POE) formulation [2] [3].
- Skills:
- Robot Kinemaitics, Optimization
- Python, MATLAB