Origami-Inspired Robotic Manipulator
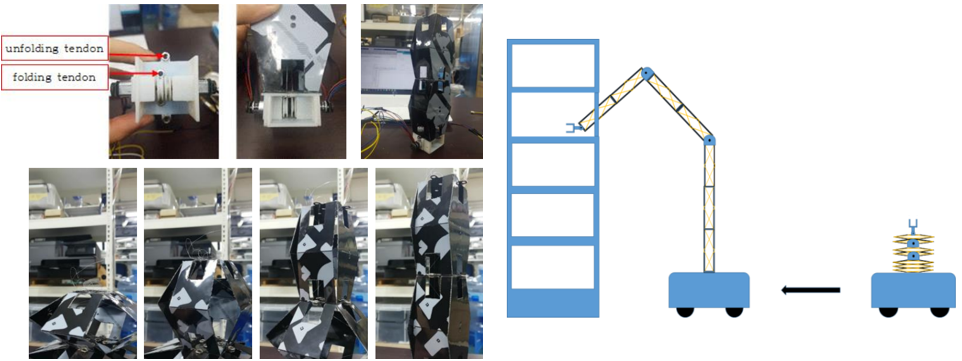
Development of an origami-inspired robotic manipulator with a folding and unfolding mechanism. This design enhances mobility in the folded state for mobile robots and improves manipulability in the unfolded state, making it suitable for volume-efficient and human-interactable applications such as warehouse operations.
- Thesis
- Motivation
- The lack of an unfolding mechanism in An origami-inspired, self-locking robotic arm limits its applications to drone-based robotic arms.
- The demand for lightweight, volume-efficient robotic manipulators capable of human interaction in warehouse environments.
- Contributions
- Designed elongated folded lines using the origami perpendicular principle to avoid over-folded states.
- Achieved a functional folding and unfolding mechanism applicable to mobile robotic manipulators, increasing mobility in the folded state and enhancing manipulability in the unfolded state.