Robust Wearable Visual-Inertial Hand Motion Tracking Interface
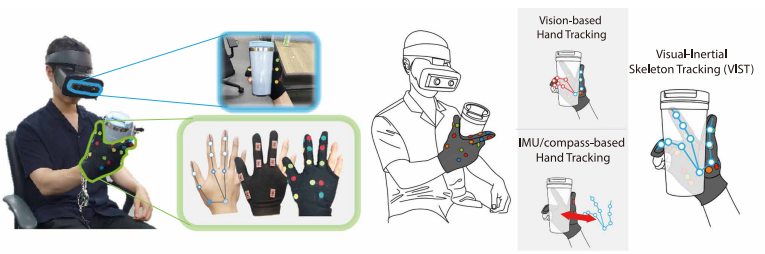
Robust hand tracking system fusing complementary strengths of visual and inertial sensors. The system addresses limitations of individual sensing modalities and provides an effective solution for Human-Robot Interaction (HRI) interfaces.
- Motivation
- Vision-based tracking systems face challenges such as occlusion and dependence on extensive datasets.
- Wearable-based tracking systems are limited by issues like magnetic interference, lack of global position tracking, and the need for frequent and cumbersome calibration due to sensor bias.
- Contributions
- Developed a filtering-based state estimation algorithm that opportunistically integrates visual and inertial sensor data.
- Achieved a robust hand tracking system by leveraging the complementary properties of visual and inertial sensors, making it suitable for HRI interfaces.
- Skills:
- Computer Vision, Inertial Measurement Unit (IMU), Extended Kalman Filter (EKF).